Enterprise aircraft diagnosis
A DJI Matrice repair decision must begin with the exact aircraft, payload, controller, batteries, dock or field kit and mission requirement. Matrice 30, Matrice 300 RTK and Matrice 350 RTK share an enterprise role, but they do not share every assembly, interface or acceptance test. This guide turns a fleet concern into a documented diagnostic path without treating one warning as a parts order.
Quick answer
Identify the complete enterprise system before diagnosing one component
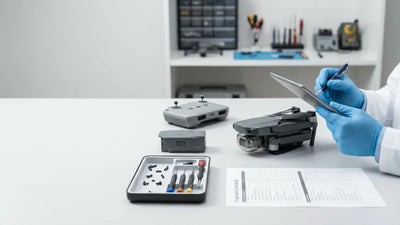
Record the exact Matrice model and revision, controller, payload, battery pair, charging equipment, firmware context, event history and mission effect. Separate aircraft, payload, positioning, link and power evidence before approving work. Reboot Hub reports confirmed findings, unresolved risks, repair scope and return-to-service tests in writing so an operator can make an operational decision, not just a component decision.
DJI Matrice series · price after diagnosis
No validated public range is available for this model. Share its condition, fault, and photos to receive a written quote.
What evidence should be captured before the customer acts?
How does repair-bench experience map the fault domains?
Which Matrice system is actually being repaired?
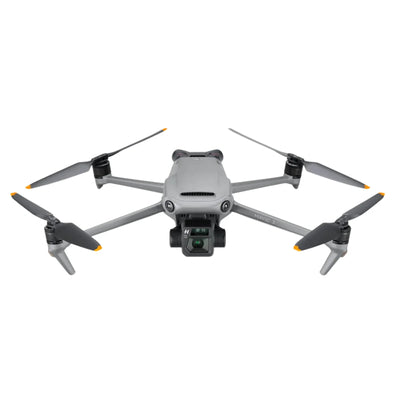
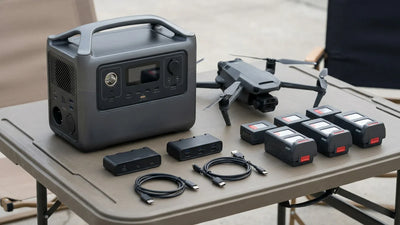
Start with the product label and the physical system. Matrice 30 and Matrice 30T are compact integrated enterprise aircraft; Matrice 300 RTK and Matrice 350 RTK support modular payload configurations and different fleet workflows. Record the exact aircraft, controller, payload, RTK context, battery model, charging hardware and accessories that arrived. A family name is not a compatibility statement, and a replacement assembly cannot be approved merely because it is described as Matrice-compatible.
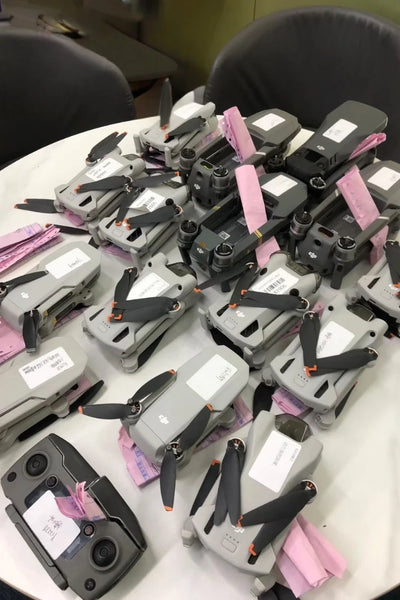
Configuration evidence also protects the customer from scope drift. Photograph the intact kit, identifiers, ports, mounts, battery bays and visible condition before disassembly. Note any missing component and whether the complaint occurs with one payload, battery pair or controller. A case-level part number, chip identifier or measured value may be disclosed when it belongs to the documented model and board revision; it must not be generalized across the entire Matrice family.
How should a no-power or battery warning be divided?
Treat a no-power event as a chain: battery pair, latch and terminals, communication, charger history, aircraft input path, regulated power domains and the system that requests power. Compare supported healthy equipment only when the exact model and safety condition permit it. Record LED and app behavior, temperature, physical damage and whether the concern follows one pack, one bay or the airframe. Stop on swelling, liquid evidence, burnt odor, deformation or abnormal heat.
Enterprise downtime can tempt a team to jump directly to a core board, yet a connector, harness, charger, pack relationship or local power stage may produce similar symptoms. Bench diagnosis should state which boundary was tested and what remains unknown. It should never publish energized-board service procedures. The customer receives a repair or replacement recommendation tied to measured evidence, part provenance and the operational cost of unresolved power risk.
What separates propulsion, arm and ESC faults?
A propulsion warning can involve a propeller, motor, bearing, wiring path, connector, drive channel, current feedback, command path or structural alignment. Inspect the complete load path from the propeller and motor mount through the arm, hinge or frame. Compare channels and record impact evidence before assigning the warning to an ESC. An aircraft that looks straight at rest can still have alignment, harness or connector damage after a load event.
Matrice aircraft carry mission and payload consequences beyond a single motor replacement. The written scope should state whether work is mechanical, electrical, structural or combined, and whether the affected assembly can be validated to the required mission standard. A confirmed MOSFET or driver finding on a dated board revision can appear as repair experience, but it is evidence for that board and event rather than a universal remedy for every motor warning.

How are RTK, GNSS, compass and IMU concerns separated?
Positioning errors must be reproduced with the environment recorded. Structures, vehicles, power equipment, magnetic material, sky view and correction-service context can affect observations without proving an aircraft defect. Capture the exact warning and compare GNSS acquisition, RTK state, heading consistency, IMU state and mission impact. A calibration request is a test result to interpret, not permission to conceal impact or hardware damage.
For Matrice 300 RTK and Matrice 350 RTK workflows, positioning is part of a larger chain that includes antennas, modules, connectors, core processing, controller data and mission setup. The diagnosis should show which parts of that chain were observed. If a local component or board domain is confirmed, disclose the exact configuration and test boundary. The return gate must verify stable positioning behavior in an appropriate controlled environment before a mission owner accepts the aircraft.
When is the payload the fault rather than the aircraft?
Record the payload model, mount, locking condition, connector condition, power-up behavior, image, recording, stabilization and control functions. Determine whether the concern follows the payload, the aircraft port or a particular configuration. Do not force a mount or repeatedly cycle an unstable connection. Bent interfaces, contamination, impact, moisture and prior repair can affect both mechanical seating and data behavior.
Matrice payload diagnosis is strongest when aircraft and payload evidence remain distinct. A payload-side camera, gimbal or interface fault should not be sold as an aircraft core-board repair, and an aircraft port fault should not be hidden by swapping payloads. The quote names the failed boundary, proposed assembly or component work, any calibration dependencies and the post-repair payload functions that will be demonstrated.
How should vision and obstacle-sensing warnings be tested?
Document which direction and sensor group reports the warning, the surface, illumination, contamination, weather and aircraft attitude. Clean only with supported non-damaging methods and inspect windows, brackets, harnesses and surrounding structure. A warning that appears in low texture, glare or unsuitable light is different from one that persists in controlled conditions. Impact can alter alignment without an obvious external break.
The acceptance test should begin with safe ground observations, supported calibration state and consistent sensor reporting, then progress only when the aircraft is suitable. It must not claim that one successful hover proves every directional sensor or automated mission function. For fleet use, state the tested environment, the functions exercised and any condition that was not reproduced so the operator understands the evidence boundary.
What evidence belongs in controller and transmission diagnosis?
Identify the controller and aircraft pairing, antennas, cable or network context, firmware relationship and operating environment. Separate failure to pair, intermittent telemetry, image loss, control warning and environmental interference. Record whether the concern follows one controller, one location, one payload or the aircraft. Do not treat advertised range as a bench target or a promise for a real site.
A link repair should be accepted through staged checks that include stable pairing, telemetry, control response, image where applicable and the mission functions relevant to the customer. If the finding is a connector, antenna path, radio assembly or board component, the record should name the exact model and board revision. If interference cannot be excluded, that unknown must remain visible instead of being converted into an unsupported hardware conclusion.
What makes a Matrice return-to-service decision credible?
Acceptance begins with the original concern and then checks adjacent systems affected by access, impact or replacement. Match the returned aircraft, payload, controller, batteries and accessories to the intake record. Confirm hardware links, warnings, power behavior, gimbal or payload functions, positioning, propulsion observations and controlled flight only when safe and appropriate. A mission-specific function should be included when it was part of the approved scope.
The handover should distinguish a repaired fault from an aircraft approved for every mission. Reboot Hub provides written findings, parts provenance, tests, remaining observations and warranty scope. Fleet managers can then decide whether to return the system to service, restrict it to a defined role, retain it as a spare or replace it. That transparent decision path is more valuable than a generic repair label.
Keep exploring
Further reading
From The Reboot Hub Chronicle
From Drone Guides