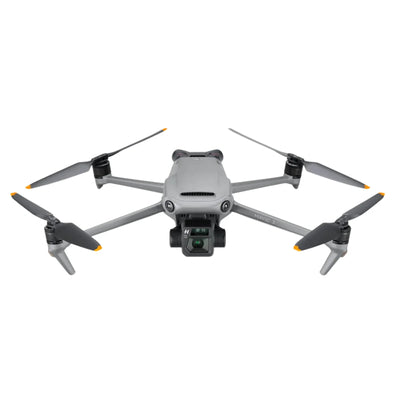
DJI Matrice 4E Technical Mapping Guide: Camera, RTK and Fleet Planning
Updated 1 October 2026. Source-based editorial analysis using the Matrice 4 Series manual v1.2 (April 2025) and maintenance guidance v1.0 (January 2025), where relevant. Calculations are illustrative, not flight-test results. Document editions are identified so readers can check their installed configuration.

The DJI Matrice 4E is a photographic mapping and inspection aircraft whose usefulness depends on the complete capture-to-delivery workflow. Its wide camera, mechanical shutter and RTK capability support image acquisition, but an aircraft specification alone does not establish the accuracy or suitability of a finished map. Buyers should define the deliverable, capture conditions, correction source, processing method and acceptance evidence together.
This guide connects those decisions. It is intended for businesses evaluating a first mapping system, expanding a fleet or comparing a proposed package with the work it must perform.
Start with task fit, then choose the model
Our suggested starting question is: what must the customer be able to do with the delivered data? An orthomosaic used for visual progress reporting has a different acceptance requirement from a dataset used to measure dimensions or compare surfaces over time. Define the required coverage, detail, coordinate system, accuracy evidence and file formats before choosing the capture package.
The Matrice 4E and Matrice 4T share a family name but have different imaging priorities. The official specifications list the 4E wide camera as a 4/3-inch, 20-megapixel camera with a mechanical shutter. The 4T wide camera is a 1/1.3-inch, 48-megapixel camera, and the 4T additionally has a thermal imager. The manual's camera diagram also identifies the 4T's NIR auxiliary light. DJI camera specifications; user manual, PDF page 29.
| Requirement | What to evaluate |
|---|---|
| Photographic mapping | 4E capture configuration, image quality, route design, processing and independent acceptance checks. |
| Thermal inspection | The 4T thermal workflow, including interpretation and task-specific requirements; the 4E is not a thermal-camera substitute. |
| Scanning LiDAR survey | A suitable LiDAR collection system. A laser rangefinder does not turn the 4E into a scanning LiDAR payload. |
| Close visual inspection | Required detail and viewpoint, available clearance, sensing conditions and the ability to obtain evidence without assuming collision protection. |
Reboot Hub's decision logic: choose for the output you must defend, rather than the largest isolated number in a comparison table. More pixels, RTK availability or a sophisticated flight mode cannot replace a defined acceptance method.
Camera specifications that affect acquisition
For the 4E wide camera, DJI lists a mechanical-shutter range of 2 seconds to 1/2000 second. Its interval options begin at 0.5 seconds for JPEG and 2 seconds for JPEG + RAW. These are mode-specific capture specifications, not promises that every route can use the fastest interval under all conditions. DJI camera and still-photography specifications.
The practical dependency is straightforward: flight speed and capture interval determine the distance traveled between successive exposures. For example, a hypothetical aircraft moving at a constant 6 m/s travels 3 metres in 0.5 seconds and 12 metres in 2 seconds. This calculation is illustrative, not a recommended speed or a measured Matrice 4E performance result. To determine overlap, that spacing must be considered alongside the image footprint and scene geometry.
Mechanical shutter choice also does not eliminate motion blur. The acquisition plan still needs an appropriate exposure and sufficient image quality. Treat camera settings, speed and route parameters as connected decisions; changing image format can affect the interval choices available to the plan.
The manual recommends checking camera settings and taking test images before important capture. Our handover recommendation is to verify that a small representative image set can be opened, inspected and processed in the intended software before committing a large assignment. User manual, PDF page 30. For the shutter mechanism itself, read our mechanical versus rolling shutter explanation.
RTK is one dependency, not the finished result
The manual describes a built-in RTK module used with a separately purchased D-RTK product or an approved network RTK service. It requires the RTK function to be enabled and the correct service type selected. Custom network RTK also needs controller internet access and the relevant NTRIP connection details. PDF page 35; PDF page 36.
A buyer should therefore ask who provides corrections, where the service is available, what subscription or site setup is needed and how connection problems will be handled. An aircraft-only price cannot answer those questions. A network service and a local station are different operational arrangements; neither should be assumed to be included without an explicit package list.
The manual explains that FIX indicates the aircraft has obtained and used network differential data. That is useful positioning evidence, but it does not independently verify the final map. Our recommendation is to retain acquisition records and agree how the finished output will be checked against appropriate independent references. The required method depends on the deliverable and professional requirements.
For a deeper explanation of corrections and positioning, see RTK versus GPS for drones. Use this guide to decide how that capability fits into the purchase, rather than treating the RTK label as a substitute for an accuracy specification.
Routes, terrain and model-based capture
The manual describes Smart Oblique as an image-acquisition approach using multiple camera angles. It also describes terrain following to adjust flight altitude as terrain changes. For Real-Time Follow, the documented recommendation includes suitable vision conditions and terrain slope below 75 degrees. These conditions matter: a feature description is not permission to apply the same route everywhere. PDF page 77.
That slope figure is conditional. Manual PDF page 78 identifies cliffs, steep slopes, power lines and towers as unsuitable for Real-Time Follow. Vision-dependent operation also requires suitable lighting and surface conditions; rain, snow, fog, reflective water and low-texture surfaces can prevent normal operation.
Our planning interpretation is to ask where the altitude reference comes from and whether it represents the surface relevant to the assignment. A route over changing terrain needs more attention than simply selecting one height number. Keep a distinction between ground, structures and the required image detail on each surface.
Smart 3D Capture uses a rough model of the subject to generate three-dimensional photographic routes, according to the manual. That makes the input model and proposed route part of the review, rather than something to accept without inspection. PDF page 84.
Obstacle assistance remains conditional. The manual states that obstacle avoidance is disabled in Sport mode and gives environmental limits for vision. This does not establish that every sensing component is physically powered off. Do not use a successful demonstration around one building as proof of safe automatic behavior at another. Review the actual route, mode, surfaces and clearance. PDF page 25; PDF page 46.
A purchase and handover matrix
We recommend agreeing the following evidence before purchase. This is a proposed commercial handover framework, not a DJI certification or a report that Reboot Hub has tested a particular customer's site.
| Decision | Evidence to agree | Unresolved issue to avoid |
|---|---|---|
| Required output | Coverage, detail, coordinates, accuracy criterion and delivery formats. | Buying hardware before defining success. |
| Capture configuration | Camera format, exposure approach, interval and representative image review. | Assuming the fastest interval suits every format. |
| Positioning | Correction source, account or station requirements and connection procedure. | Assuming RTK service is included. |
| Processing | Software compatibility, licensing, computer resources and a small sample workflow. | Collecting data without a workable delivery path. |
| Acceptance | Independent checking method, responsible reviewer and retained evidence. | Using GSD or FIX alone as proof of accuracy. |
| Ownership | Battery and consumable quantities, maintenance records, service route and downtime plan. | Comparing only the aircraft price. |
Review the DJI Matrice 4E product listing at Reboot Hub against this matrix. Confirm the actual supplied configuration and relevant compatibility details before treating any accessory, service or software as part of the package.
Build maintenance into the operating calendar
The maintenance manual separates usage-based basic maintenance from a defined standard service interval. Standard maintenance is recommended every 200 flight hours or annually, whichever occurs first; the annual period refers to device activation time. DJI notes that regional service arrangements can change. Maintenance manual, PDF page 8.
| Item | Trigger | Reference |
|---|---|---|
| Standard maintenance | 200 flight hours or annually, whichever comes first. | PDF page 8. |
| Propellers | Replace immediately for specified damage; also replace after over 200 flight hours or one year of use. | PDF page 9. |
| Battery maintenance | Every 50 cycles, more than three months idle, or an app maintenance prompt; any trigger calls for attention. | PDF page 14. |
| Battery replacement | Recommended after 200 cycles; damage or persistent faults can require earlier replacement. | PDF page 15. |
Do not wait for a calendar date when inspection finds damage. Our fleet recommendation is to record aircraft hours, activation date, individual battery cycles and last use separately. A lightly flown aircraft can reach its annual service point, while an idle battery can reach a maintenance trigger without accumulating flights. These intervals are maintenance guidance, not a guarantee of remaining component life.
Keep firmware claims dated
The release-note entry dated 10 July 2026 lists aircraft firmware v17.02.05.01, controller firmware v01.64.08.20 and DJI Pilot 2 v17.2.5.28. These numbers identify that release combination; they are not a promise that it remains the newest combination whenever this article is read. Check DJI's download page before deployment. Release notes, PDF page 1; DJI downloads.
The manual states that battery firmware is included with aircraft firmware and that all batteries should be updated. Include the whole working set in the handover record, not only the aircraft. User manual, PDF page 95. Historical known-issue documents should retain their dates and firmware scope; they do not establish current behavior without further evidence.
Our method and further reading
This is Reboot Hub's source-based technical analysis of DJI documentation, with original buying and workflow recommendations. It does not claim independent flight tests, measured mapping accuracy or professional certification. The distance calculation is explicitly illustrative. Manufacturer facts are linked near the relevant statements; operational advice remains subject to the applicable instructions and requirements.
Our detailed RTK and shutter articles are linked above. The companion article on GSD versus accuracy is scheduled for 3 October 2026, and the article on forward versus side overlap for 10 October 2026, both at 21:30 Hong Kong time. Those forthcoming explanations address individual mechanisms; this guide connects them to the overall purchase decision.
Frequently asked questions
Is the Matrice 4E a LiDAR mapping drone?
The photographic workflow discussed here uses cameras and image reconstruction. Do not confuse the camera assembly's laser rangefinder with a scanning LiDAR survey payload. Choose a system designed for the required sensing method rather than assuming the two data types are interchangeable.
Does RTK FIX guarantee the accuracy of my map?
No. The manual describes FIX as evidence that network differential data has been obtained and used. The delivered map still needs a suitable capture and processing workflow and an agreed independent acceptance check. Specify the accuracy requirement separately from the positioning status.
Why does JPEG versus RAW matter to route planning?
DJI lists different minimum interval options for JPEG and JPEG + RAW on the 4E wide camera. At the same speed, a longer interval means more travel between exposures. Revisit the required overlap and footprint when changing format; do not assume an unchanged route preserves the same coverage.
Should I choose the 4E or 4T?
Start with the required data. The 4E's wide camera and mechanical shutter are relevant to photographic mapping; the 4T adds thermal imaging. Compare a complete workflow for your task rather than choosing solely by pixel count or treating both models as identical imaging systems.
What should be included in a commercial quotation?
Ask for an explicit aircraft and accessory list, battery provision, correction-source requirements, processing software assumptions, training or handover scope and service arrangements. State which items are included, optional or customer-supplied so competing quotations can be compared fairly.
Can low annual usage eliminate maintenance needs?
No. The manual includes time-based and condition-based triggers as well as flight hours and battery cycles. Track them separately. Annual service timing, battery idle time and visible damage can require attention even when the aircraft has flown relatively little.
Keep exploring
Further reading
From تاريخ Reboot Hub
From أدلة الطائرات بدون طيار