Drone Obstacle Sensing Explained: Detection, Avoidance and Real-World Limits
Updated 1 October 2026. Source-based editorial analysis using the Matrice 4 Series manual v1.2 (April 2025) and maintenance guidance v1.0 (January 2025), where relevant. Calculations are illustrative, not flight-test results. Document editions are identified so readers can check their installed configuration.
Read the DJI Matrice 4E technical mapping guide

Drone obstacle sensing collects information about nearby objects; obstacle avoidance uses available information to influence flight. Neither guarantees that an aircraft will detect every hazard or prevent every collision. Useful assistance depends on the sensors, their coverage, the scene, the selected operating configuration and the space available for a response.
This companion to our video explains the engineering principles and turns them into questions for enterprise buyers and operators. The DJI Matrice 4 Series provides a documented example; the explanation is not a report of Reboot Hub flight testing.
Sensing, avoidance and operational judgment are different
A useful purchasing discussion separates three questions: what can the aircraft observe, what can it do with those observations, and what must the operator decide? Combining them into one checkbox marked “obstacle avoidance” hides differences that matter when planning an inspection.
| Layer | Question it addresses | Evidence to request |
|---|---|---|
| Obstacle sensing | What observations are available? | Sensor arrangement, coverage and documented operating conditions. |
| Flight assistance | What response is available in this configuration? | Model-specific behavior, settings and mode restrictions. |
| Operational judgment | Should this route be flown under these conditions? | A site assessment, clearance plan and defined reasons to stop or change the task. |
For procurement, ask for an explanation of a realistic assignment rather than only a demonstration of an aircraft stopping in front of a convenient obstacle. The task might involve a building facade, a narrow access corridor or a change in lighting. Each raises different questions about the proposed workflow.
How stereo vision estimates depth
Stereo vision compares images from cameras separated by a known baseline. A scene point appears in different positions in the two views. That displacement, called disparity, can be combined with camera geometry to estimate distance. In a simplified calibrated stereo model, depth is proportional to focal length multiplied by baseline and divided by disparity.
The crucial step is establishing which features in the images belong to the same physical point. This is a measurement process, not an understanding of the object's purpose or importance. Stereo is also one approach to sensing, not an explanation of every sensor on every aircraft. OpenCV's stereo-depth tutorial explains the underlying geometry.
What coverage specifications actually mean
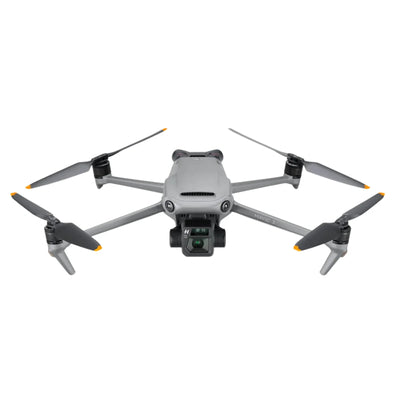
DJI describes the Matrice 4 Series sensing arrangement as omnidirectional binocular vision, supplemented by a downward 3D infrared sensor. Its specifications list direction-specific fields of view, measurement ranges and operating conditions. The environmental requirements include suitable surface texture and illumination. Read these entries together rather than treating the word “omnidirectional” as unconditional protection. See DJI's Matrice 4 Series sensing specifications.
Our recommendation is to put the intended flight direction beside the relevant documentation. A team planning sideways inspection passes should explicitly discuss that movement, rather than relying on a forward-flight demonstration. Repeat the exercise for ascent, descent and the intended return route. This makes the procurement conversation specific enough to identify unanswered questions.
Why the environment matters
The Matrice 4 Series manual identifies challenging situations including transparent or reflective surfaces, weak or repetitive texture, extreme lighting and small obstacles such as branches and power lines. It also warns against relying on the system to identify cable-and-frame structures accurately. These are documented limitations, not hypothetical failure claims about a test we performed. Consult the user manual's sensing-system notices.
For a site review, translate those categories into a written observation list: glazing on the facade, cables crossing the route, repetitive cladding, shaded sections and surfaces that change appearance with viewing angle. The purpose is to decide where the original plan needs more clearance, another viewpoint or a different method.
A successful pass on one occasion is not evidence that every later pass is equivalent. Record the circumstances that mattered to the decision. This also makes handovers more useful: the next operator receives an explanation of the route, rather than an unsupported statement that the aircraft “handles it automatically.”
Detection still needs time and distance
Receiving an observation does not instantly remove the aircraft's motion. Information must be interpreted, a response commanded and speed changed. As a simple kinematic illustration, an aircraft moving at 10 metres per second travels two metres in 0.2 seconds before accounting for subsequent braking. Those numbers are illustrative, not a Matrice 4 latency or stopping-distance specification.
This distinction matters when comparing a detection range with available clearance. The range alone does not tell you where an aircraft will stop. Avoid calculating a universal safe speed from a headline sensing distance; use the applicable instructions and assess the actual task.
DJI's manual requires continued operator attention and control. It also describes low-light limitations and cautions that Vision Assist is a reference aid whose display may not represent glass or small objects accurately. Review those notices before relying on the displayed view.
Matrice 4 settings: check the mode as well as the sensor
The Matrice 4 Series manual identifies omnidirectional vision, downward vision and a downward 3D infrared sensing system. That arrangement does not mean every surface is measurable from every direction under every condition. The manual says the vision system works best with adequate lighting and clearly marked or textured obstacles. It describes automatic activation in Normal or Tripod mode when Obstacle Avoidance Action is set to Avoid or Brake. DJI user manual, PDF page 45.
Sport mode changes the assumption: obstacle avoidance is disabled. This describes the available flight assistance; it should not be interpreted as a claim that every sensing component is physically powered off. DJI also warns that maximum speed and braking distance increase in this mode. A fleet briefing should therefore name the flight mode and obstacle-action setting, not simply state that the aircraft has sensors. Do not transfer expectations from Normal mode into a faster flight mode. PDF page 25; PDF page 26.
There is a separate setting nuance: when Vision Positioning and Obstacle Avoidance are disabled, the manual says the aircraft relies on GNSS to hover, loses omnidirectional obstacle avoidance and does not automatically slow its descent near the ground. However, the manual says this disable setting applies to manual flight and does not take effect in automatic modes such as RTH or automatic landing. That distinction does not guarantee those automatic modes will succeed when environmental requirements are unmet. PDF page 45.

Vision Assist, avoidance and RTH serve different purposes
| Function | What the manual describes | Operational implication |
|---|---|---|
| Vision Assist | A view from vision sensors that can follow flight direction or be locked to a direction. | A display aid is not evidence that the path is clear. |
| Obstacle assistance | Sensing and flight responses subject to settings and operating conditions. | Confirm the actual mode, action setting and system availability. |
| Return to Home | An automatic return process with its own settings, positioning needs and limitations. | Assess the return route before departure and monitor the return. |
Vision Assist may be unavailable with a weak video-transmission signal. DJI specifically warns that glass walls and small objects may not be displayed accurately. The view can also be locked in a direction rather than automatically following current motion. Operators should understand what the displayed view represents before using it to inform a maneuver. PDF page 47; PDF page 48.
RTH does not remove environmental limits. The manual warns that obstacles cannot be sensed during RTH when conditions are unsuitable for the sensing system, and that an overly complex environment may cause RTH to exit even when sensing works. A return plan therefore needs more than a Home Point: review the route, altitude setting, obstacles and available landing options. PDF page 38; PDF page 39.
Turn the limitations into a site decision
Reboot Hub's practical interpretation: write down where the operation depends on reliable scene information. A facade task may include textured masonry, featureless panels, reflective glazing and thin rooftop structures within one route. Treat these as separate planning conditions rather than assigning the whole building a single “suitable” label. This is our suggested review method, not a DJI test procedure or a claim that we have flown the site.
- Before departure: inspect the sensor windows, check the app's system status and confirm the planned mode. DJI instructs users to remove obstructions and keep sensing-system glass clean; damaged lenses require support attention. PDF page 47.
- For each route segment: record surface type, lighting, thin objects, clearance and the intended direction of motion. Identify an alternative viewpoint where the original plan depends on uncertain detection.
- For changing conditions: agree in advance which warnings or observations require pausing the task. Examples include loss of an expected sensing function, repeated unexplained warnings, worsening visibility or inability to maintain the planned clearance.
- For stopping the task: identify a suitable retreat or landing option in the operating plan. A warning should trigger assessment; it is not a reason to push closer to discover whether an object is real.
These proposed pause conditions supplement the manufacturer's instructions. They are not permission to operate outside them. In particular, the manual prohibits flight in rain, smog or visibility below 100 metres. It also warns that low light can make vision unavailable. A usable camera image does not establish that the sensing system has adequate conditions. PDF page 47.
Response distance is a planning concept, not a published braking specification
The earlier two-metre example comes only from distance equals speed multiplied by time: 10 m/s × 0.2 s = 2 m. It assumes constant speed during that interval. It excludes subsequent braking, wind, control behavior and uncertainty about when a hazard becomes detectable. Neither input is presented as a measured Matrice 4 response characteristic. Do not turn this illustration into a clearance recommendation or a universal stopping-distance calculator.
Keep document versions attached to operational claims
This section uses User Manual v1.2, dated April 2025. Before a deployment, compare it with DJI's current documentation and the installed aircraft, controller and DJI Pilot 2 versions. An old issue report describes its named firmware combination; it does not prove the same behavior persists today. Preserve the distinction between an evergreen sensing principle, a documented model instruction and a version-specific issue.
Sources and related product
- DJI Matrice 4 Series specifications — sensing arrangement and operating conditions.
- DJI Matrice 4 Series user manual — sensing-system notices and operational limitations.
- OpenCV stereo-depth tutorial — disparity and depth geometry.
Considering an enterprise aircraft? Review the DJI Matrice 4T product page at Reboot Hub, then match the configuration to your intended task. Reboot Hub's interpretation here is independent editorial analysis, not a DJI endorsement.
Read the DJI Matrice 4E technical mapping guide
Frequently asked questions
Does Matrice 4 obstacle avoidance work in Sport mode?
The publicly linked v1.2 manual says obstacle avoidance is disabled in Sport mode and warns of increased braking distance. This is a limitation on the assistance available, not a claim about every sensor's electrical state. Confirm the active mode before relying on obstacle assistance. PDF page 25; PDF page 26.
Does the manual-flight obstacle-avoidance disable setting also apply during RTH?
The manual says the Vision Positioning and Obstacle Avoidance disable setting takes effect only during manual flight, not automatic modes such as RTH or automatic landing. Environmental limits still apply. PDF page 45.
Can Vision Assist confirm that glass or wires are absent?
No. DJI describes Vision Assist as a reference and warns that glass walls and small objects cannot be displayed accurately. An apparently clear view is not clearance evidence. PDF page 47.
Will RTH always find a safe path around obstacles?
No. The manual states that unsuitable sensing conditions prevent obstacle sensing during RTH, and an overly complex environment can cause RTH to exit. Plan and monitor the return rather than treating it as guaranteed recovery. PDF page 38; PDF page 39.
Does the downward auxiliary light make vision reliable in darkness?
No. The manual warns that vision positioning may remain suboptimal in low light even when the auxiliary light is on. Do not infer adequate sensing conditions from the light being illuminated. PDF page 46.
What should the team do with unexpected sensing warnings?
Maintain control, assess the surroundings and follow the app and aircraft instructions. Our planning recommendation is to define pause and landing options before the flight, so the response does not depend on improvising close to an obstacle. DJI requires continuing operator attention and judgment. PDF page 46.
Keep exploring
Further reading
From De Reboot Hub-kroniek
From Drone-gidsen