RTK vs GPS for Drones: Precise Positioning and Its Limits
Updated 1 October 2026. Source-based editorial analysis using the Matrice 4 Series manual v1.2 (April 2025) and maintenance guidance v1.0 (January 2025), where relevant. Calculations are illustrative, not flight-test results. Document editions are identified so readers can check their installed configuration.
Read the DJI Matrice 4E technical mapping guide

RTK is a precise positioning technique that uses satellite observations and reference information; GPS is one satellite navigation system. They are not competing replacements. An RTK-equipped drone can use GPS alongside other supported satellite systems, with corrections helping it estimate a more precise position under suitable conditions.
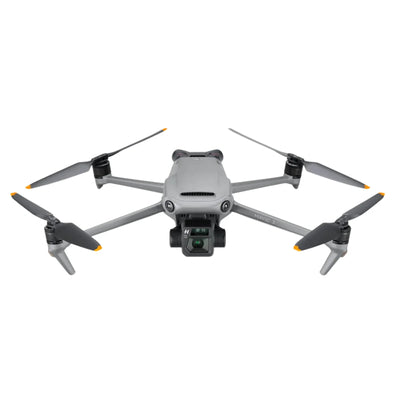
This guide accompanies our video, RTK vs GPS for Drones: How Precise Positioning Works. It explains the distinction for DJI Matrice 4E mapping teams and buyers evaluating the complete workflow behind a positioning claim.
GPS, GNSS and RTK describe different things
GNSS is the broader term for satellite navigation systems. GPS is one member of that group. A receiver estimates its location using observations from satellites, while accounting for factors such as its clock offset. RTK adds a relative positioning method using information from a reference receiver or supported reference network.
| Term | Meaning | What to ask |
|---|---|---|
| GNSS | Satellite navigation systems collectively | Which systems and signals does the equipment support? |
| GPS | One satellite navigation system | Is the specification using GPS precisely or as shorthand? |
| RTK | A real-time positioning technique using reference information | Which reference, correction link and operating conditions are required? |
How a reference station helps the drone
In a single-base arrangement, the reference receiver and moving receiver, often called the rover, observe many of the same satellites. Comparing their observations helps reduce errors they share. The method depends on reference coordinates, signal conditions and timely information reaching the rover. Local problems, such as reflected signals near one antenna, are not automatically removed.
NOAA's single-base real-time GNSS guidelines explain the underlying method and the importance of checking results. They provide background principles, rather than a current Matrice 4E operating manual.
Local base or network service?
A local base puts reference equipment near the operation. A supported network correction service supplies reference information through the configured connection instead. DJI's D-RTK 3 documentation describes its station functions and supported arrangements. Confirm the relevant aircraft, firmware, station mode and connection before purchasing; a compatible brand name alone is not a complete configuration.
Our procurement view is to compare the whole arrangement: who establishes the reference, where corrections come from, what connectivity is required and what happens if that connection fails. These questions expose responsibilities that an aircraft-only quotation can leave unclear.
Carrier phase explains fixed and float
RTK uses carrier-phase observations: measurements related to the repeating wave in a satellite signal. The receiver can observe a fractional cycle, but must also deal with an initially unknown number of complete cycles. This is the ambiguity-resolution problem.
A fixed solution has resolved the relevant ambiguities as integers; a float solution has not resolved them in that way. NovAtel's processing documentation explains this distinction. Fixed and float are processing states, not alternative coordinate systems.
Read the status together with the operational context. Losing corrections, obstructing the antenna's view or changing reception conditions can affect the solution. A previous fixed state does not establish that all later observations have the same quality. Avoid treating a green indicator as independent verification of the customer's finished deliverable.
Correct reference coordinates matter, including height
A precise relative result can still inherit an incorrect reference location. As an illustrative example, if a base is assigned coordinates displaced from the intended reference, a compact cluster of rover observations can be displaced too. Repeatability and correct absolute placement are different requirements.
NovAtel's base-transmission documentation identifies accurate antenna phase-centre coordinates as important for producing accurate correction information. Antenna setup and offsets deserve explicit treatment, rather than being hidden inside a generic “RTK ready” description.
Do not treat all height values as interchangeable
Ellipsoidal height and a height referenced to an appropriate geoid or vertical datum are not the same quantity. Record the input and output coordinate reference systems, units and required height reference. Apply the supported transformation for the project instead of manually shifting data until it looks aligned. Pix4D's vertical-coordinate documentation explains the available geoid and height-reference choices in its workflow.
RTK positioning is not the accuracy of the finished map
The camera position is one input to photogrammetry. The final reconstruction also depends on photographs, geometry, calibration and processing. Good positioning cannot recreate a blurred feature or reveal a surface that was never adequately photographed. Likewise, a visually sharp orthomosaic does not demonstrate correct coordinates.
Assess the output with suitable independent checkpoints withheld from fitting the reconstruction. Keep their reference quality, distribution and intended accuracy assessment in the project record. Pix4D distinguishes relative and absolute accuracy; its checkpoint example shows why external checks belong in the evaluation.
For Matrice 4E, read DJI's official specifications in their stated context. An RTK GNSS specification is not automatically a horizontal and vertical accuracy guarantee for every map produced with the aircraft.
Matrice 4E: verify the correction workflow and the recorded photographs
The following workflow is grounded in the Matrice 4 Series User Manual v1.2, April 2025, and the D-RTK 3 User Manual v1.0, January 2025. These are the documented editions reviewed for this article, not a claim that they are the newest firmware instructions. Check the documentation matching your installed configuration before operating.
Separate an internet connection from a usable RTK solution
The Matrice manual's PDF page 36 specifies that Custom Network RTK requires the controller to communicate with both the aircraft and the internet. It describes Wi-Fi or a DJI Cellular Dongle 2 with a nano-SIM, selection of the correct RTK service and connection to the designated NTRIP server. The aircraft's FIX indication confirms that differential information has been obtained and used. A connected hotspot by itself does not establish this state.
For the documented Area Route orthophoto procedure, PDF page 85 calls for RTK to be enabled, connected and fixed before capture. Our practical recommendation is to retain the service configuration and initial positioning state with the mission record, then examine the captured dataset for changes. Do not substitute a screenshot taken before flight for evidence covering the photographs actually delivered.
Use per-image evidence to find interruptions
PDF page 91 documents RtkFlag values: 0 denotes unsuccessful positioning, 16 a single-point solution, 32–49 a float solution and 50 a fixed solution. It also lists RtkDiffAge and the position standard-deviation fields. These are useful diagnostic records. The manual does not supply a universal correction-age acceptance threshold for every mapping project, so one should not be invented from these field names.
Preserve the original images and associated positioning files. PDF page 93 identifies the .MRK image log, including exposure-related timing, compensated coordinates, ellipsoid height and positioning status. It separately describes the .rtk observation file. Their availability gives a processor more evidence to investigate; it does not mean an arbitrary loss of corrections can always be repaired afterwards.
A reproducible check: count affected photographs, then locate them
Suppose a hypothetical dataset contains 800 photographs: 760 report RtkFlag 50, 28 report a float value and 12 report 16. The fixed share is 760 ÷ 800 × 100 = 95%; 40 photographs, or 5%, were not fixed. Those percentages alone cannot determine acceptance. Forty consecutive non-fixed photographs along one critical strip have a different consequence from forty scattered observations supported by neighbouring images. Plot the affected exposures against the mission and investigate their role in the reconstruction. This is an example of our review method, not a DJI pass threshold or a field result.
| Observation | Action before accepting the mapping result |
|---|---|
| Controller online, but aircraft not FIX | Check service selection and correction connection; do not call the documented capture prerequisite satisfied. |
| Non-fixed flags appear in the image sequence | Locate their times and coverage; review the processing treatment and independent checks. |
| Fixed positions, but consistent checkpoint displacement | Investigate reference coordinates, height system and transformations before blaming image resolution. |
| D-RTK 3 used to measure checks | Record pole setup and reference method, and keep checkpoints out of the fitting set. |
Make the station configuration part of the purchase
The D-RTK 3 manual, PDF page 13, distinguishes base, relay and rover modes and requires the rover pole-height setting to match the physical setup. PDF page 14 describes checkpoint export as UTF-8 CSV. A relay deployment and a checkpoint-survey workflow are different jobs; ask which mode, accessories and records the proposed package includes. Our acceptance table is editorial guidance, not a claim of independent measurement.
Finally, DJI's Matrice specifications express fixed RTK GNSS accuracy with a constant plus 1 ppm term. For an illustrative 5,000 m baseline, 5,000 × 0.000001 m = 0.005 m, or 0.5 cm. Adding this term gives 1.5 cm horizontally and 2.0 cm vertically in that specification's arithmetic. This is baseline-dependent receiver-specification arithmetic, not an error budget or guarantee for the finished map.

Sources and further reading
- NOAA NGS: Single-base real-time GNSS guidelines
- DJI: D-RTK 3
- DJI: Matrice 4 Series specifications
- Pix4D: Vertical coordinate systems and geoids
Read the DJI Matrice 4E technical mapping guide
Frequently asked questions
What should I check before a Matrice 4E orthophoto mission?
The reviewed manual's PDF page 85 requires enabled, connected RTK in FIX state for its documented collection procedure. Confirm the selected service and reference configuration, then retain evidence from the actual captured dataset as well as the initial state.
How can I identify photographs that were not captured with fixed RTK?
Where the documented metadata is present, inspect RtkFlag. PDF page 91 defines 50 as fixed, 32–49 as float, 16 as single-point positioning and 0 as unsuccessful positioning. Missing metadata is unknown evidence, not a fixed solution.
Is 95% fixed RTK sufficient?
There is no universal acceptance rule based on that percentage. Review where the remaining photographs occur, how processing treats them and whether independent checks support the required deliverable.
What does 1 ppm mean in the positioning specification?
It contributes one millimetre per kilometre of baseline. At 5 km, that term is 5 mm. It belongs to the stated positioning specification, not to a blanket accuracy claim for every mapped point.
Can D-RTK 3 serve as a base and measure checkpoints?
The reviewed D-RTK 3 manual distinguishes base and rover operating modes. Its rover workflow supports checkpoint measurements and export, with the pole-height setting matching the actual setup. Verify supported equipment, software and operating mode.
Does a fixed solution prove that the coordinate and height references are correct?
No. Check the reference setup and transformations separately. The Matrice image log documents ellipsoid height; a project's required elevation reference may require a properly configured transformation before comparison.
Keep exploring
Further reading
From A Reboot Hub Chronicle
From Drone Guides